

Range (Roll ±180°, Pitch ±90°, Azimuth ±180°)
Roll & Pitch Dynamic accuracy:±0.1°
Static accuracy of roll and pitch:±0.05°
<CAN2.0A/CAN2.0B output Optional
IP67/IP68 Protection Optional
DC 9~36V wide voltage input
Wide temperature operation -40℃~+85℃

 Product Description

 Scope of application

 Parameter

 Dimensions

 Download
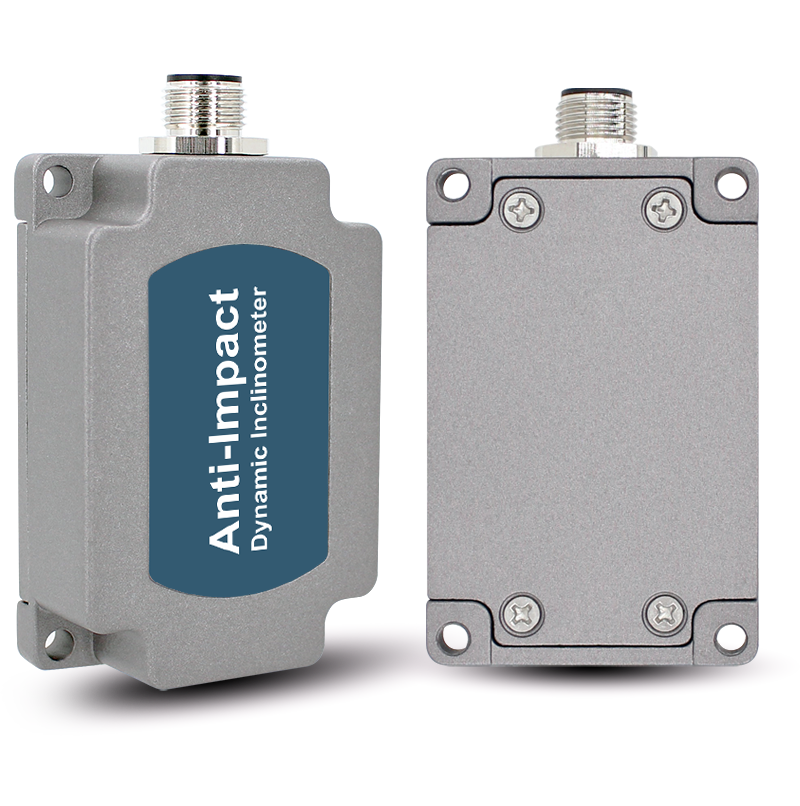
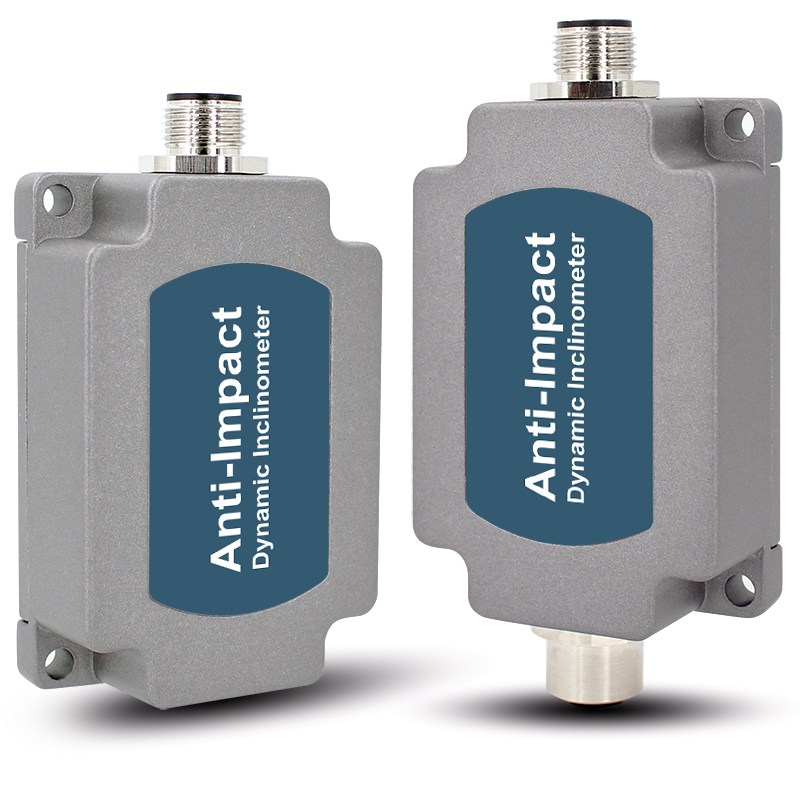
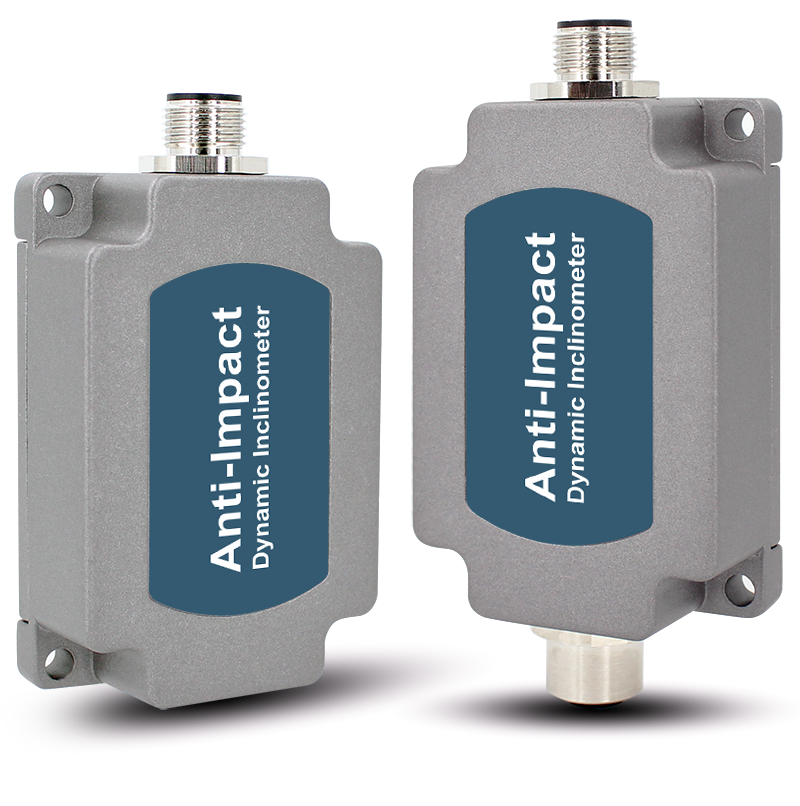
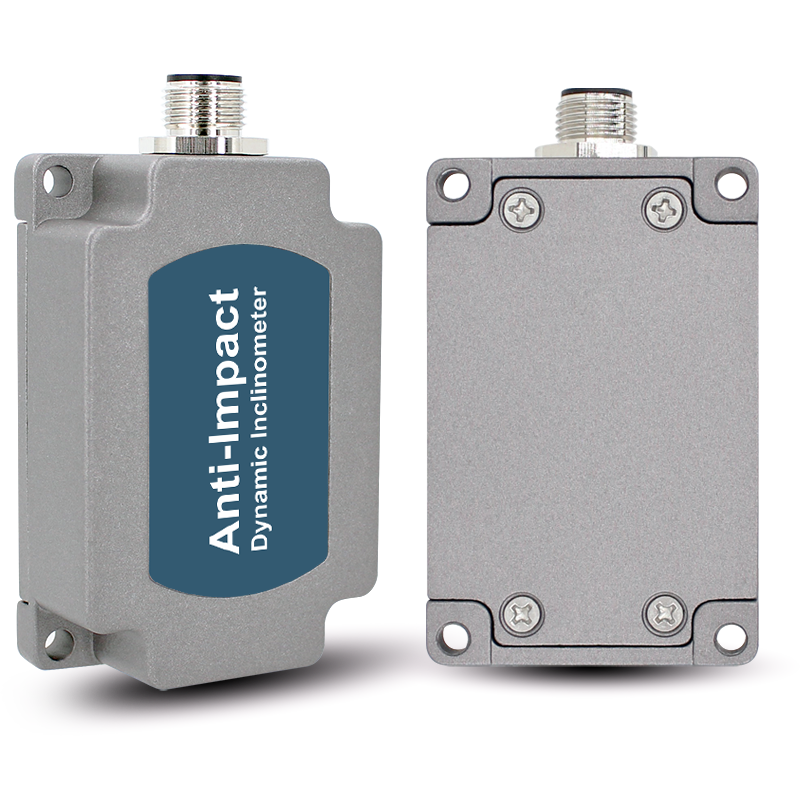
The HDA446T product is a new generation of digital MEMS dynamic tilt sensor, which can measure the attitude parameters (roll, pitch, and azimuth) of a moving carrier and is suitable for tilt measurement in motion or vibration states. The HDA446T is equipped with built-in acceleration and gyroscope sensors, and integrates the Kalman filter algorithm to measure real-time motion data of the carrier under motion or vibration conditions. The product has dual CAN (CAN2.0A/CAN2.0B) modes and strong scalability.
This product adopts non-contact measurement principle , it can output the current posture inclination angle in real time. It is easy to use and does not require retrieving the installation of two surfaces with relative changes. Internally integrated high-precision AD and gyroscope units can compensate for nonlinearity, orthogonal coupling, temperature drift, and centrifugal acceleration in real time, greatly eliminating centrifugal errors caused by motion acceleration interference, improving product dynamic measurement accuracy, and adapting to work in complex motion scenes and harsh environments for a long time. This product belongs to the dual-mode measurement sensor of dynamic and static, with strong resistance to external electromagnetic interference. It is suitable for various large-scale high-intensity impact vibration industrial environments and is an ideal choice for industrial automation control measurement posture.


| HDA446T-C2/C3 | Condition | Parameter | |
| Measurerange | | Roll ±180°, pitch ±90°, azimuth ±180° (initial value at power-down is 0°) | |
| Measureaxis | | X axis / Y axis / Z axis | |
| Roll&PitchStatic accuracy | @25℃ | ± 0.05° | |
| Roll&PitchDynamic accuracy(RMS)1) | @25℃ | ± 0.1° | |
| Gyro | range | - | ±300°/s |
| Zero bias stability (10ssmooth) | - | 8.5°/h | |
| Angle random walk coefficient(Allan) | - | 0.25°/sqrt(h) | |
| Acceleration | range | - | ±4g/ ±16goptional |
| Bias stability(10s mean) | - | 0.02mg | |
| Bias instability(Allan) | - | 0.005mg | |
| Speed random walk coefficient(Allan) | - | 0.005m/s/sqrt(h) | |
| Zero point temp. Coefficient2) | -40~85℃ | ±0.01°/℃ | |
| Sensitivity temp. Coefficient3) | -40~85℃ | ≤100ppm/℃ | |
| Power-on startup time | ≤3.5S | ||
| Response time | 0.01S | ||
| Output signal | CAN2.0A/CAN2.0B | ||
| Electromagnetic compatibility | According to EN61000 and GBT17626 | ||
| MTBF | ≥98000 hours / time | ||
| Insulation resistance | ≥100 Megohm | ||
| Impact resistance | 100g @ 11ms, 3 axial direction (half sinusoid) | ||
| Anti-vibration | 10grms/10~1000Hz | ||
| Waterproof level | Standard IP67, optional IP68 and corrosion-resistant IP68 protection level | ||
| Weight | Single connector≤165g/double connector≤180g(Without cable) | ||
| 1)Accuracy: refers to the root mean square difference between the measured and actual angle value by multiple measurements (>16 times) under normal temperature. 2)Zero temp.drift coefficient: the change rate of the indication value relative to normal temperature within the rated operating temperature range of the sensor at the zero degree. 3)Sensitivity temp.drift coefficient: The percentage change rate with temperature of the full-scale indication relative to the full-scale indication at room temperature of the sensor in its rated operating temperature range. | |||
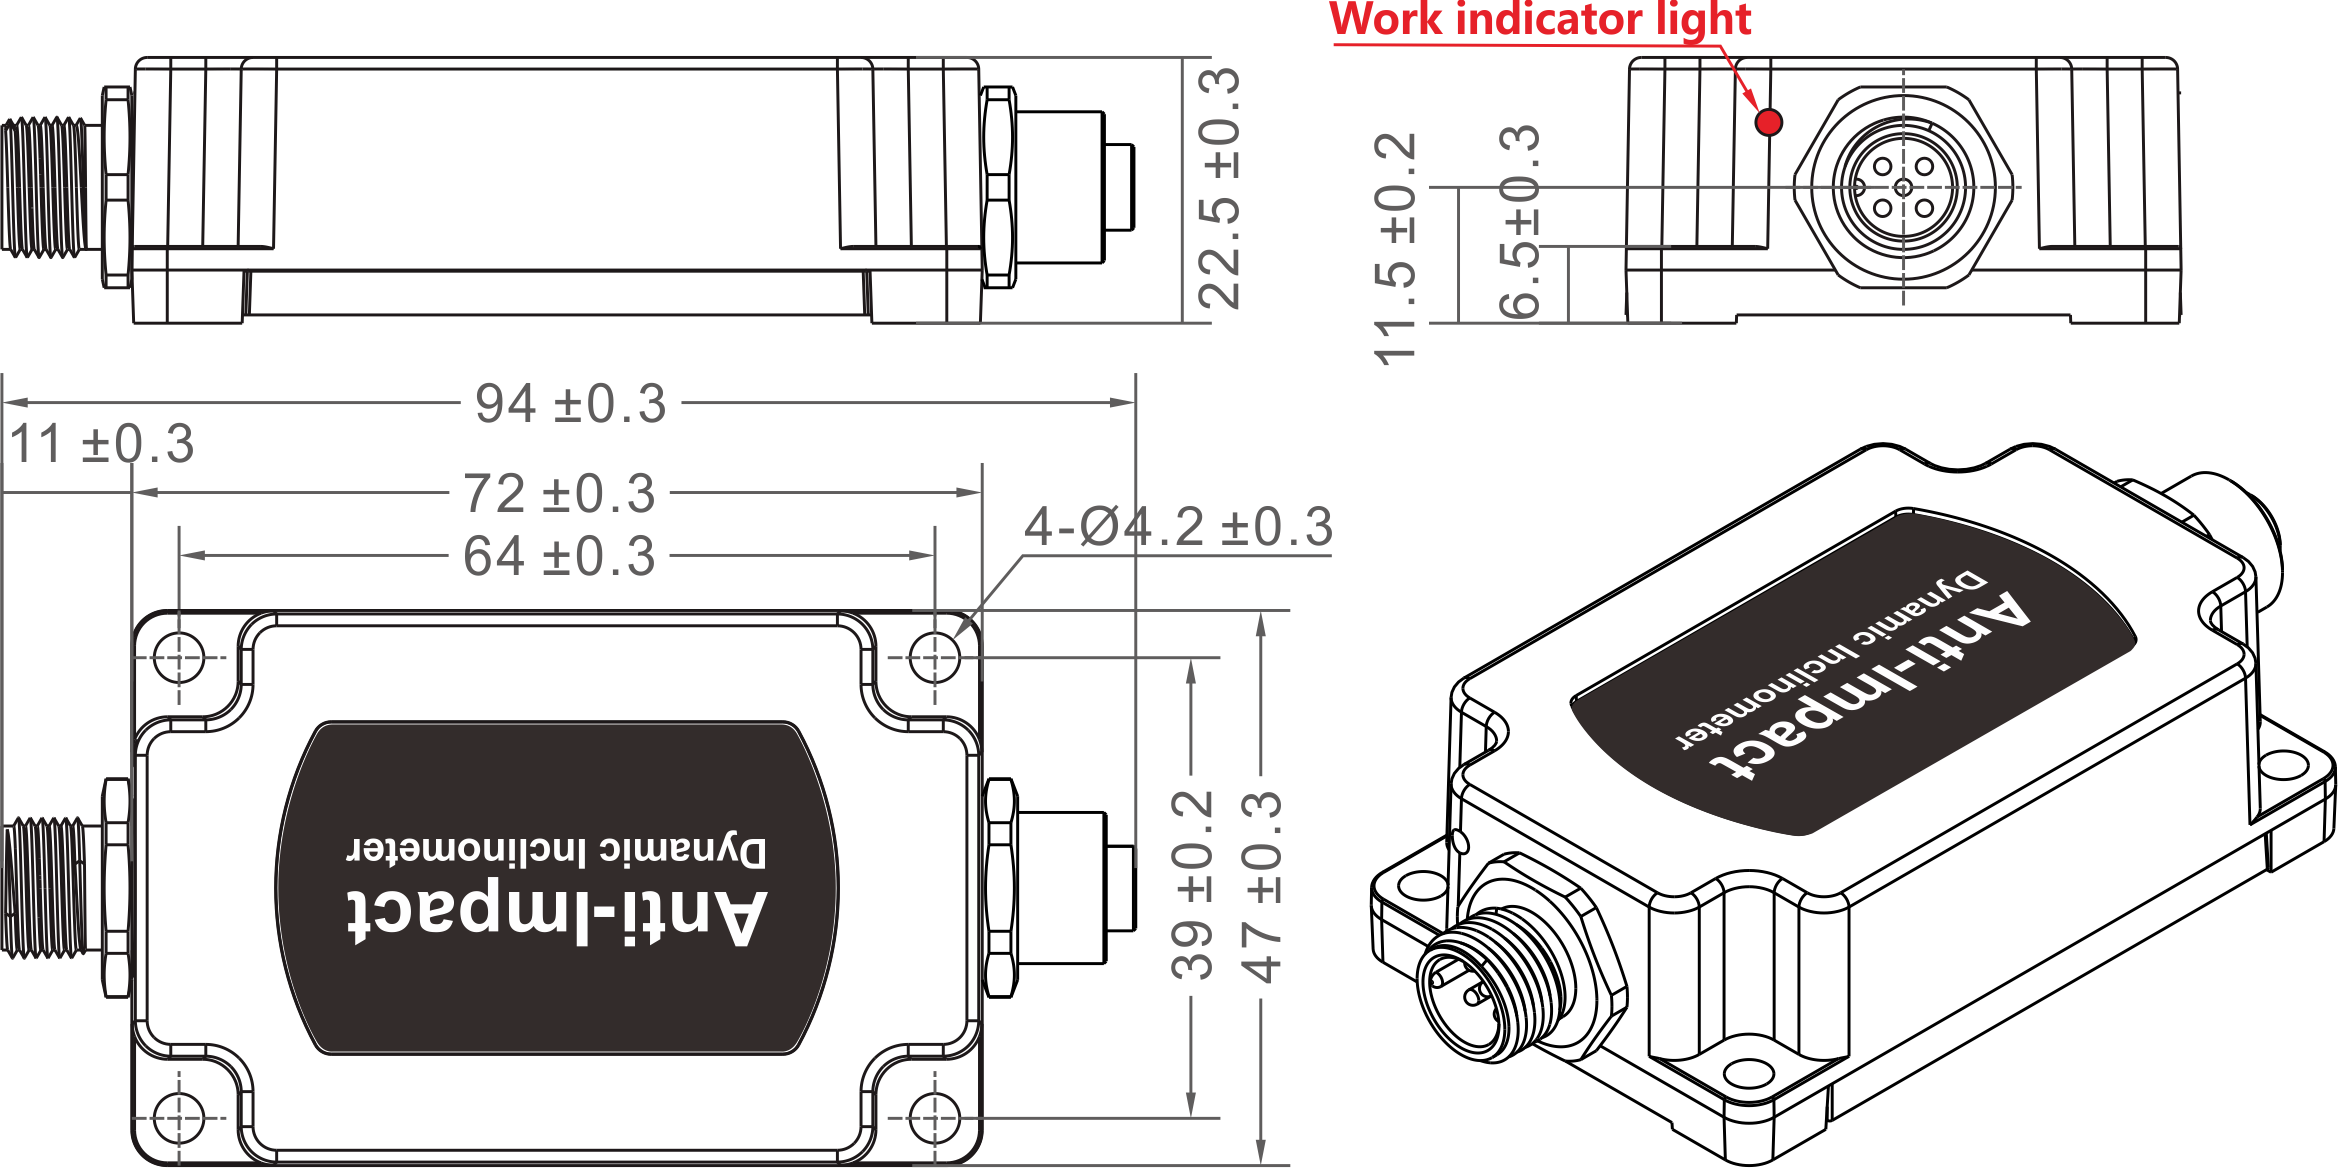
L94×W47×H22.5mm
L64×W39×H6.5mm
4 M4 screws
* Please contact the online sales engineer to obtain the product specification of Rion, or email sales@rion-tech.net to obtain it.

File Location: Download Specifications /HDA Dynamic series/HDA446T CAN2.0A/B
DYNAMIC TILT SENSOR
Update Time: 2026-09-16 09:54
File Size: 3.4MB
File Format:

Copyright © RION TECHNOLOGY